Data Driven Learning and Control seminar series is organized by the Information and Decision Science Lab at Cornell University and aims to explore the latest advancements and interdisciplinary approaches to data-driven learning and control systems.
Watch on YouTube Live
Adaptive Motion Control for Autonomous Vehicles in Uncertain Environments
A central challenge for Autonomous vehicles is enabling them to drive safely and efficiently despite incomplete perception, uncertain vehicle models, and unpredictable behavior from other road users. While current approaches combine model-based control, trajectory planning, probabilistic prediction, and data-driven methods, they can still struggle when uncertainty, rare scenarios, and strict real-time requirements occur at the same time. This talk explores how autonomous vehicles can adapt their motion control to uncertain and dynamic driving environments. The focus is on robust, learning-enabled, and safety-aware approaches based on Model Predictive Control (MPC), with a particular emphasis on more closely integrating sensor information, environmental uncertainty, and vehicle control.
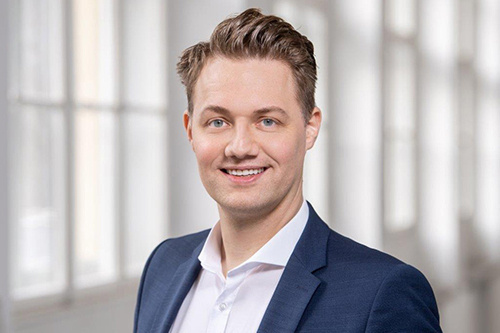
Bio: Johannes Betz studied automotive engineering at Coburg University of Applied Sciences (B.Eng., 2013) and the University of Bayreuth (M.Sc., 2013), as well as Philosophy of Science and Technology at the Technical University of Munich (M.A., 2019). From 2013 to 2018, Johannes was a research associate at the Technical University of Munich, where he earned his Dr.-Ing. degree in 2019 with a dissertation on the “Evaluation of an Intelligent Fleet Dispatching System for Mixed Vehicle Fleets.” From 2018 to 2020, he was a postdoctoral researcher at the Chair of Automotive Technology at the Technical University of Munich, where he founded the TUM Autonomous Motorsport team, which has since competed successfully in international competitions. From 2020 to 2022, he was a postdoctoral researcher at the University of Pennsylvania, where he worked in the xLab for Safe Autonomous Systems. In 2023, he was appointed Rudolf MöÃÂbauer Professor at the Technical University of Munich, where he holds the Professorship of Autonomous Vehicle Systems in the Department of Mobility Systems.
Betz’s research focuses on holistic software development for mobile robots and autonomous vehicles with the goal of developing the next generation of intelligent autonomous systems. By developing new algorithms for environmental awareness, path and behavior planning, and control, these robots will be able to interact with each other and with humans while operating safely, efficiently, and powerfully. A big focus of his research is the integration of Ai-based techniques to achieve end-to-end models. With these innovative algorithms, it will be possible to efficiently and effectively make the right decisions, especially in complex and uncertain environments. Simulation environments and various real-world vehicle platforms like autonomous cars, quadruped robots, and humanoids are used to generate data and validate these algorithms. With real-robot deployment, safe and trustworthy autonomy will be enabled across a wide range of highly integrated robotic applications.