Global Optimization for Robotics in the Age of Learning
Optimization is the bedrock of robotics, and robotics is a great stress test for optimization methods. High dimensionality, nonconvexity, and nonsmoothness make many robotics problems notoriously hard to solve, whether with learning-based or model-based strategies.
In this talk, I will discuss our recent advances in bringing learning-based techniques together with optimization principles. First, I will present extensions of moment-based optimization to data-driven, nonparametric problems that retain partial global optimality guarantees. I will discuss how these methods enable new approaches to high-dimensional, contact-rich manipulation. Next, I will explore how foundation models can be combined with global optimization to reduce modeling burdens and improve generalization of model-based solvers. I will conclude with an outlook on using optimization principles to reshape latent geometry for world-model learning. Together, these examples illustrate how learning can expand the reach of optimization, while optimization can bring structure and guarantees to data-driven robotics.
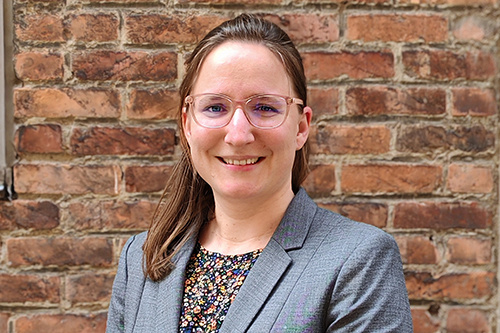
Bio: Frederike Dümbgen is an assistant professor in the Department of Mechanical Engineering at Carnegie Mellon University, where she leads the Trustworthy Robotics, Intelligence, and Optimization (TRIO) Lab. Her research combines optimization and artificial intelligence to develop scalable and trustworthy robotic systems, with a particular emphasis on global optimization and optimality guarantees.
Before joining Carnegie Mellon, she was a researcher in the WILLOW team at Inria Paris and a postdoctoral fellow at the Robotics Institute of the University of Toronto. She holds a Ph.D. in computer and communication sciences from ÃÂcole polytechnique fédérale de Lausanne (EPFL), Switzerland, where she also earned her B.Sc. and M.Sc. in mechanical engineering. She was an RSS Pioneer in 2024 and received a Google Women Techmakers Scholarship in 2020. She serves as a co-chair of the IEEE Robotics and Automation Society’s Technical Committee on Optimization for Robotics.